Nikolay Nikolov

I am a PhD student in Robotics at INSAIT, where I am advised by Danda Paudel, Luc Van Gool and Marc Pollefeys. I am also supported by a Google DeepMind fellowship and advised by Jie Tan. My research focuses on vision-language-action models (VLAs), world-action-models (WAMs), reinforcement learning (RL) and dexterous manipulation.

Previously, I was one of the first AI Applied Scientists at Wayve, where I worked on foundation models for autonomous driving and developed the first offline RL method capable of handling the streets of central London. I graduated with an MEng in Computer Science and Electronic Engineering from Imperial College London, with an exchange year at ETH Zurich, where I was advised by Andreas Krause and Stefan Leutenegger.

Profile photo of Nikolay Nikolov

Selected Research Projects

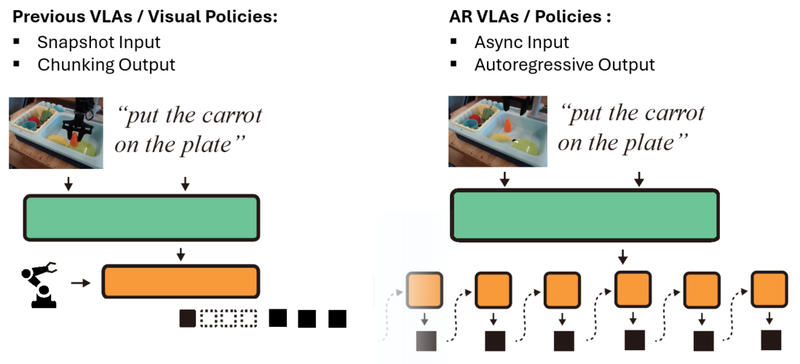
AR-VLA teaser figure
AR-VLA: True Autoregressive Action Expert for Vision-Language-Action Models
Yutong Hu, Jan-Nico Zaech, Nikolay Nikolov, Yuanqi Yao, Sombit Dey, Giuliano Albanese, Renaud Detry, Luc Van Gool, Danda Pani Paudel
Robotics: Science and Systems (RSS), 2026
project page / arXiv

A standalone autoregressive action expert that generates actions as a continuous causal sequence with long-lived memory, bridging fast low-level control and slow vision-language reasoning.
SPEAR-1: Scaling Beyond Robot Demonstrations via 3D Understanding
Nikolay Nikolov, Giuliano Albanese, Sombit Dey, Aleksandar Yanev, Luc Van Gool, Jan-Nico Zaech, Danda Pani Paudel
IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), 2026
project page / arXiv / models

A robot foundation model that scales beyond robot demonstrations by enriching easy-to-collect non-robotic image data with 3D annotations, giving its VLM backbone the 3D spatial understanding required for embodied control. Featured in WIRED.

Generalist Robot Manipulation beyond Action Labeled Data
Alexander Spiridonov, Jan-Nico Zaech, Nikolay Nikolov, Luc Van Gool, Danda Pani Paudel
Conference on Robot Learning (CoRL), 2025
project page / arXiv

Learning manipulation from videos without action labels by extracting dense 3D point dynamics at the hand or gripper, improving open-vocabulary performance and enabling data-efficient learning of new tasks.

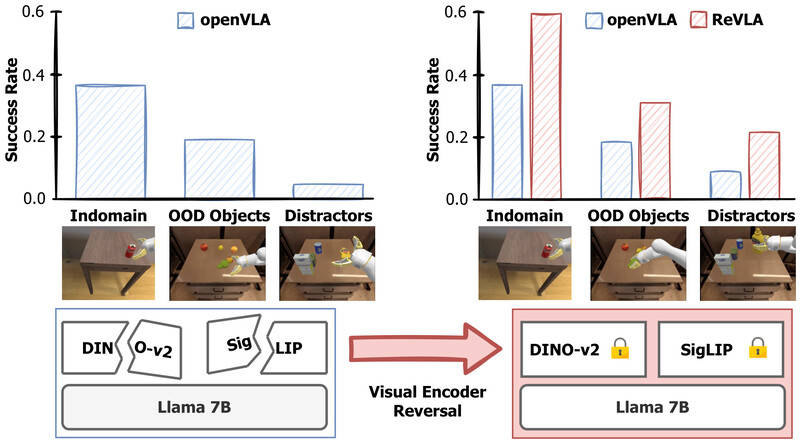
ReVLA teaser figure
ReVLA: Reverting Visual Domain Limitation of Robotic Foundation Models
Sombit Dey, Jan-Nico Zaech, Nikolay Nikolov, Luc Van Gool, Danda Pani Paudel
IEEE International Conference on Robotics and Automation (ICRA), 2025
project page / arXiv

A study of visual out-of-domain robustness in robotic foundation models, and a model-merging approach that reverts their visual encoders to the original robust pretrained state.

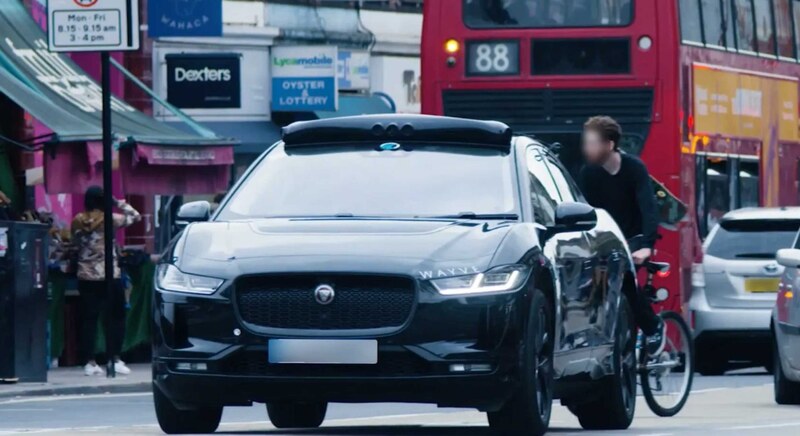
Wayve autonomous vehicle driving in London
Urban Driving with Conditional Imitation Learning
Jeffrey Hawke*, Richard Shen*, Corina Gurau*, Siddharth Sharma*, Daniele Reda*, Nikolay Nikolov*, Przemyslaw Mazur*, Sean Micklethwaite*, Nicolas Griffiths*, Amar Shah*, Alex Kendall*
IEEE International Conference on Robotics and Automation (ICRA), 2020
arXiv / video

The first end-to-end learned system capable of driving a real car in complex urban environments, trained with conditional imitation learning from human demonstrations.

Atari exploration results
Information-Directed Exploration for Deep Reinforcement Learning
Nikolay Nikolov, Johannes Kirschner, Felix Berkenkamp, Andreas Krause
International Conference on Learning Representations (ICLR), 2019
arXiv

Exploration via information-directed sampling, accounting for both parametric uncertainty and heteroscedastic return noise; outperforms C51, QR-DQN and IQN on Atari.

Octree-based volumetric SLAM reconstruction
Efficient Octree-Based Volumetric SLAM Supporting Signed-Distance and Occupancy Mapping
Emanuele Vespa, Nikolay Nikolov, Marius Grimm, Luigi Nardi, Paul H. J. Kelly, Stefan Leutenegger
IEEE Robotics and Automation Letters (RA-L) and ICRA, 2018
pdf / video / code

A Bayesian formulation for fusing depth measurements into an octree occupancy map, released as a CPU-optimized octree library for real-time 3D reconstruction and SLAM.

Other Projects

Architecture rendering generated with diffusion models
Architecture Rendering with Diffusion Models
Research project

Automatic rendering of architectural designs with diffusion models, turning raw design mockups into photorealistic visualizations.

Wayve autonomous vehicle in central London
Offline Reinforcement Learning for Autonomous Driving in London
Research at Wayve

The first offline RL method for end-to-end autonomous driving capable of handling the streets of central London.